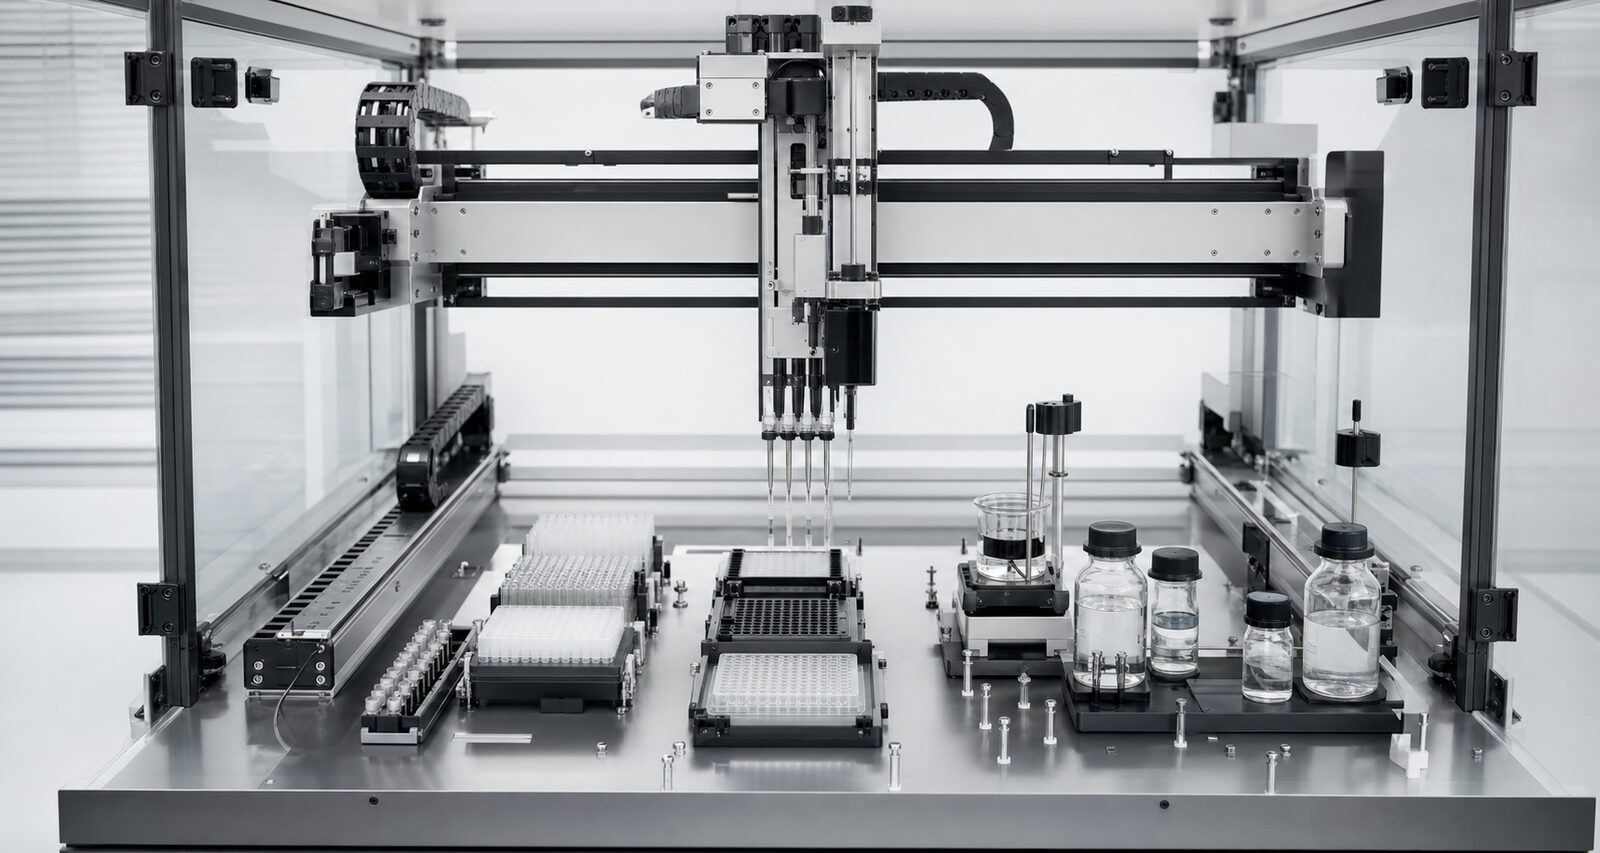
Concept only
Deterministic liquid handling
Routine sample handling, on rails.
A future enclosed gantry device for the broad class of liquid-handling interactions that no longer need a human hand: pipetting, aliquoting, timed additions, beaker mixing and sample moves — executed as deterministic, inspectable motion.
Future capability · not available yet
A protocol becomes a replayable path.
The planned device is deliberately not a general-purpose robot arm. Plates and vessels sit in registered stations beneath a rigid XYZ gantry, so each tool move, volume, dwell, mix and handoff can be bounded and checked against the protocol that requested it.
01
Register
Identify each plate, vessel, reagent position, tool, and safe motion envelope.
02
Execute
Compile the protocol into deterministic gantry moves and bounded liquid-handling actions.
03
Verify
Record calibration, actions, timing, exceptions, and visual evidence for the complete run.
Automate the interactions, not the scientific judgment.
Pipette & aliquot
Repeated transfers across tubes and plates with explicit source, destination, volume, and tool state.
Mix & time
Bounded stirring, shaking, dwell, and timed-addition steps at registered stations.
Move plates & vessels
Deterministic transfers between process positions without free-space improvisation.
Capture the run
Calibration records, action logs, images, and exception states attached to the protocol revision.
Intended verification trace
Deterministic means the system can say exactly what it did.
The future service is for routine, operator-approved interactions inside a validated envelope. It will not infer safety, diagnose, replace protocol review, or invent missing experimental conditions.
CAL
Axes, tools, stations, plates and vessels registered
PLAN
Protocol compiled into bounded actions
RUN
Volumes, positions, timing, and exceptions recorded
PROOF
Run trace and visual evidence returned for review